|
| ::rl::math::Real | delta |
| | Configuration step size. More...
|
| |
| ::rl::math::Real | epsilon |
| | Epsilon for configuration comparison. More...
|
| |
| bool | kd |
| | Use kd-tree for nearest neighbor search instead of brute-force. More...
|
| |
| Sampler * | sampler |
| |
| ::rl::math::Real | duration |
| | Upper bound for search [s]. More...
|
| |
| ::rl::math::Vector * | goal |
| | Goal configuration. More...
|
| |
| SimpleModel * | model |
| |
| ::rl::math::Vector * | start |
| | Start configuration. More...
|
| |
| Viewer * | viewer |
| |
| typedef ::boost::adjacency_list< ::boost::listS, ::boost::listS, ::boost::bidirectionalS, VertexBundle, ::boost::no_property, TreeBundle > | Tree |
| |
| typedef ::boost::adjacency_list_traits< ::boost::listS, ::boost::listS, ::boost::bidirectionalS, ::boost::listS >::vertex_descriptor | Vertex |
| |
| typedef ::std::pair< const ::rl::math::Vector *, Vertex > | QueryItem |
| |
| typedef ::CGAL::Search_traits< ::rl::math::Real, QueryItem, const ::rl::math::Real *, CartesianIterator > | SearchTraits |
| |
| typedef Orthogonal_k_neighbor_search< SearchTraits, Distance > | NeighborSearch |
| |
| typedef NeighborSearch::Tree | NeighborSearchTree |
| |
| typedef ::boost::shared_ptr< NeighborSearchTree > | NeighborSearchTreePtr |
| |
| typedef ::std::vector< NeighborSearchTreePtr > | NearestNeighbors |
| |
| typedef ::boost::graph_traits< Tree >::edge_descriptor | Edge |
| |
| typedef ::boost::graph_traits< Tree >::edge_iterator | EdgeIterator |
| |
| typedef ::std::pair< EdgeIterator, EdgeIterator > | EdgeIteratorPair |
| |
| typedef ::boost::graph_traits< Tree >::vertex_iterator | VertexIterator |
| |
| typedef ::std::pair< VertexIterator, VertexIterator > | VertexIteratorPair |
| |
| typedef ::std::pair< Vertex, ::rl::math::Real > | Neighbor |
| |
| virtual Edge | addEdge (const Vertex &u, const Vertex &v, Tree &tree) |
| |
| void | addPoint (NearestNeighbors &nn, const QueryItem &p) |
| |
| Vertex | addVertex (Tree &tree, const VectorPtr &q) |
| |
| bool | areEqual (const ::rl::math::Vector &lhs, const ::rl::math::Vector &rhs) const |
| |
| virtual void | choose (::rl::math::Vector &chosen) |
| |
| virtual Vertex | connect (Tree &tree, const Neighbor &nearest, const ::rl::math::Vector &chosen) |
| |
| virtual Vertex | extend (Tree &tree, const Neighbor &nearest, const ::rl::math::Vector &chosen) |
| |
| virtual Neighbor | nearest (const Tree &tree, const ::rl::math::Vector &chosen) |
| |
| ::std::vector< Vertex > | begin |
| |
| ::std::vector< Vertex > | end |
| |
| ::std::vector< Tree > | tree |
| |
| ::rl::util::Timer | timer |
| |

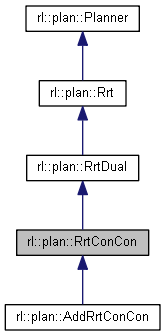
 Public Member Functions inherited from rl::plan::RrtDual
 1.8.20